An LLM agent that answers analysts' questions in SQL
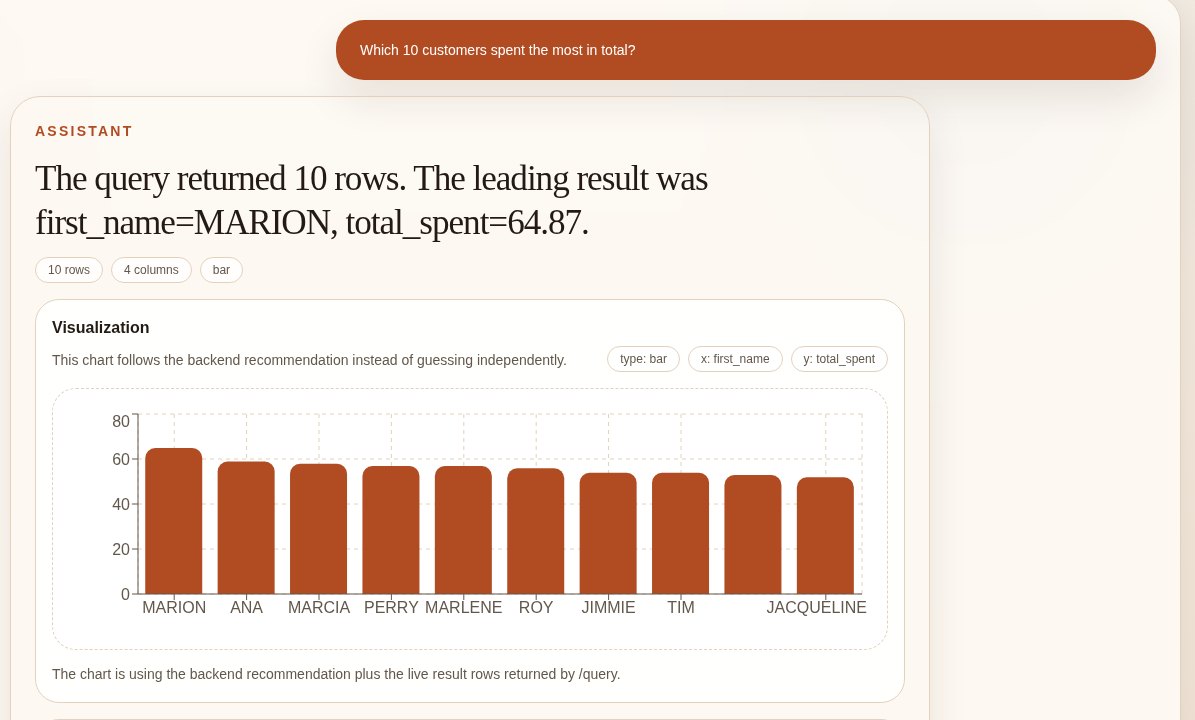
Seven tools, an internal Oracle database, and a 48-question benchmark I built to measure it. Accuracy rose from 83% to 87.5%, and routing sub-tasks to smaller models made each query about 20× cheaper than o3.
Cost per query, at similar accuracy
o3 on the whole task€5
The agent, small models on sub-tasks€0.24